Conversions between kornia and other computer vision libraries formats
Project Links
Meta
Author: Dmytro Mishkin
Requires Python: >=3.9
Classifiers
Development Status
- 5 - Production/Stable
Intended Audience
- Developers
License
- OSI Approved :: Apache Software License
Programming Language
- Python :: 3
kornia_moons


Conversions between kornia and other computer vision libraries formats, mainly OpenCV.
Documentation: https://ducha-aiki.github.io/kornia_moons/
What's inside
- Keypoint / LAF conversions — OpenCV
cv2.KeyPoint↔ kornia local affine frames (LAFs), handling the differing scale and orientation conventions (mrSize=6.0for SIFT,1.0for ORB):laf_from_opencv_SIFT_kpts,opencv_ORB_kpts_from_laf, … - Match conversions — kornia match tensors ↔
cv2.DMatchlists:cv2_matches_from_kornia,kornia_matches_from_cv2 - OpenCV detectors as kornia modules —
OpenCVDetectorKornia,OpenCVFeatureKornia,OpenCVDetectorWithAffNetKornia(with kornia AffNet shape refinement) - Visualization — LAFs (
visualize_LAF), matches with inliers/epipolar lines/reprojected corners (draw_LAF_matches), plain point matches from LoFTR-style matchers (draw_point_matches), epipolar errors, and SOLD2 line segments (plot_lines,plot_color_line_matches)
Install
pip install kornia_moons
Quick start: keypoint conversion
import matplotlib.pyplot as plt
import cv2
from kornia.image import image_to_tensor

from kornia_moons.feature import laf_from_opencv_ORB_kpts, opencv_ORB_kpts_from_laf
from kornia_moons.viz import visualize_LAF

img = cv2.cvtColor(cv2.imread('data/strahov.png'), cv2.COLOR_BGR2RGB)

det = cv2.ORB_create(500)
kps, descs = det.detectAndCompute(img, None)

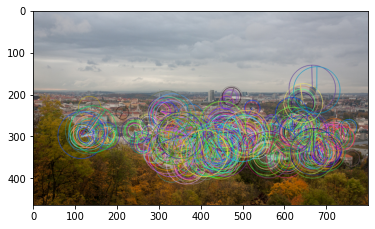
out_img = cv2.drawKeypoints(img, kps, None, flags=cv2.DRAW_MATCHES_FLAGS_DRAW_RICH_KEYPOINTS)
plt.imshow(out_img)

lafs = laf_from_opencv_ORB_kpts(kps)
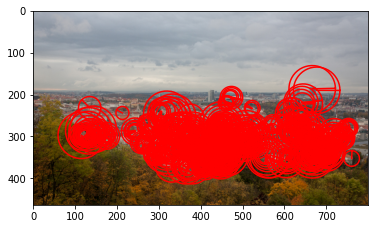
visualize_LAF(image_to_tensor(img, False), lafs, 0)

kps_back = opencv_ORB_kpts_from_laf(lafs)
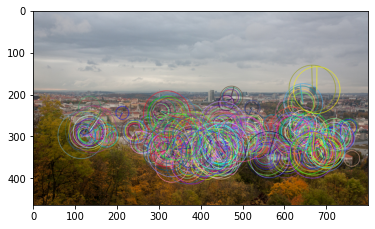
out_img2 = cv2.drawKeypoints(img, kps_back, None, flags=cv2.DRAW_MATCHES_FLAGS_DRAW_RICH_KEYPOINTS)
plt.imshow(out_img2)
Matching and visualization
import cv2
import numpy as np
import torch
import kornia

from kornia_moons.feature import laf_from_opencv_SIFT_kpts
from kornia_moons.viz import draw_LAF_matches

det = cv2.SIFT_create(100)
img1 = cv2.cvtColor(cv2.imread('data/strahov.png'), cv2.COLOR_BGR2RGB)

Hgt = np.array([[0.5, 0.1, 10], [-0.1, 0.5, 10], [0, 0, 1]])
img2 = cv2.warpPerspective(img1, Hgt, img1.shape[:2][::-1], borderValue=(255, 255, 255))

kps1, descs1 = det.detectAndCompute(img1, None)
lafs1 = laf_from_opencv_SIFT_kpts(kps1)
kps2, descs2 = det.detectAndCompute(img2, None)
lafs2 = laf_from_opencv_SIFT_kpts(kps2)

match_dists, match_idxs = kornia.feature.match_snn(
    torch.from_numpy(descs1).float(), torch.from_numpy(descs2).float(), 0.98)

H, mask = cv2.findHomography(
    kornia.feature.get_laf_center(lafs1[:, match_idxs[:, 0]]).numpy().reshape(-1, 2),
    kornia.feature.get_laf_center(lafs2[:, match_idxs[:, 1]]).numpy().reshape(-1, 2),
    cv2.USAC_MAGSAC, 0.5)

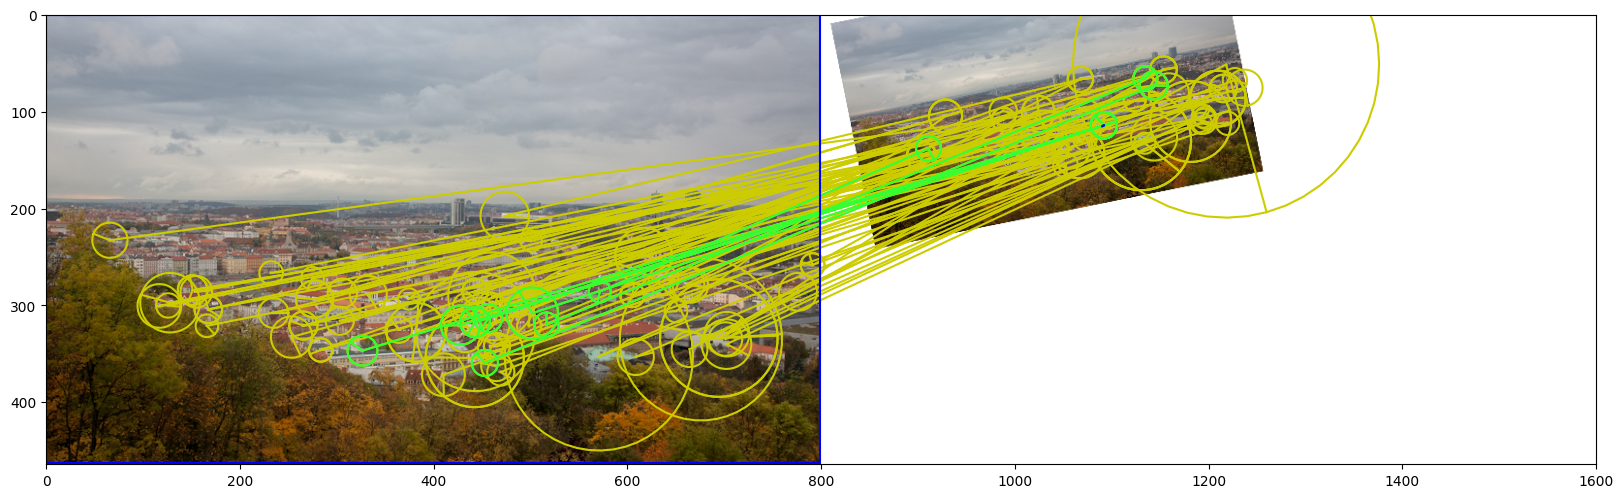
draw_LAF_matches(lafs1, lafs2, match_idxs, img1, img2, mask,
                 draw_dict={"inlier_color": (0.2, 1, 0.2),
                            "tentative_color": (0.8, 0.8, 0),
                            "feature_color": None,
                            "vertical": False}, H=H)
Learn more
- Local features tutorial — conversions in both directions, matches, detector wrappers
- Visualization tutorial — matches, epipolar geometry, SOLD2 line segments
- API reference
Development
pip install -e ".[dev]"
pytest tests                                # unit tests
pytest --nbmake docs/feature.ipynb docs/viz.ipynb   # run the docs notebooks
mkdocs serve                                # preview docs locally
0.3.0
Aug 07, 2026
0.2.9
Sep 26, 2023
0.2.8
Sep 25, 2023
0.2.7
Sep 19, 2023
0.2.6
Apr 18, 2023
0.2.5
Apr 17, 2023
0.2.4
Mar 20, 2023
0.2.3
Sep 29, 2022
0.2.2
Sep 29, 2022
0.2.1
Aug 24, 2022
0.2.0
Jun 13, 2022
0.1.9
Mar 11, 2022
0.1.8
Mar 11, 2022
0.1.7
Dec 07, 2021
0.1.6
Aug 25, 2021
0.1.5
Aug 25, 2021
0.1.4
Jul 21, 2021
0.1.3
Jun 15, 2021
0.1.2
Jun 04, 2021
0.1.1
May 07, 2021
0.1.0
May 07, 2021
0.0.1
Nov 23, 2020
